overleaf template galleryCommunity articles — Recent
Papers, presentations, reports and more, written in LaTeX and published by our community.
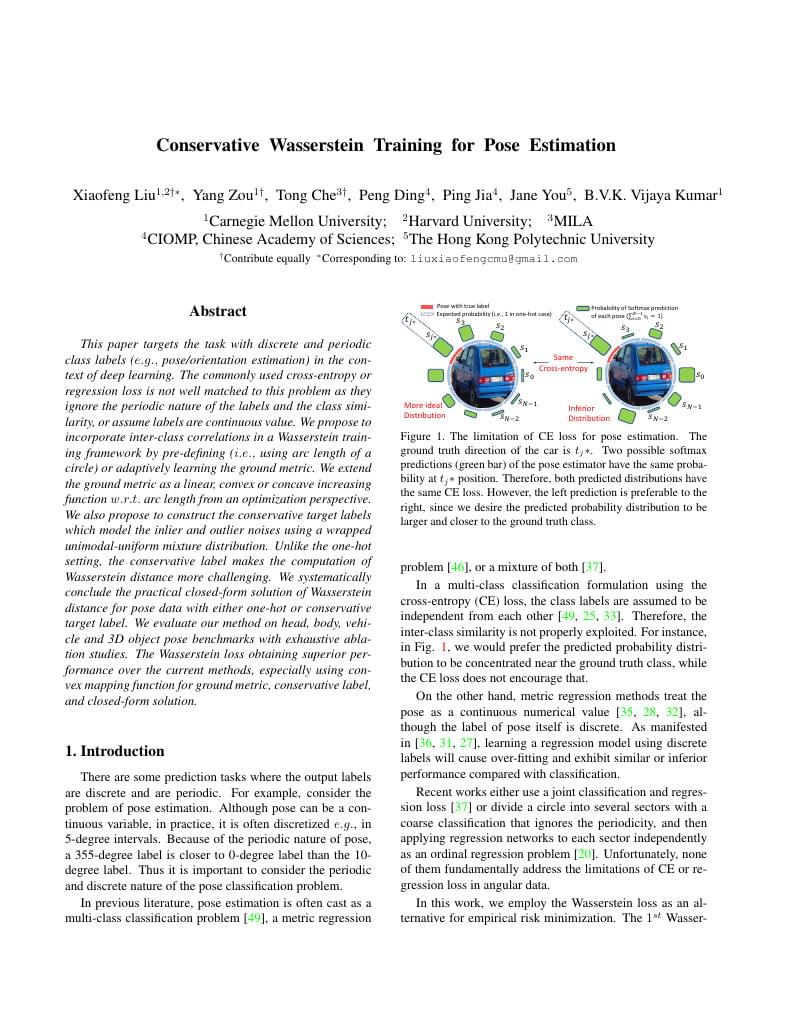
Paper presented at ICCV 2019. This paper targets the task with discrete and periodic class labels (e.g., pose/orientation estimation) in the context of deep learning. The commonly used cross-entropy or regression loss is not well matched to this problem as they ignore the periodic nature of the labels and the class similarity, or assume labels are continuous value. We propose to incorporate inter-class correlations in a Wasserstein training framework by pre-defining (i.e., using arc length of a circle) or adaptively learning the ground metric. We extend the ground metric as a linear, convex or concave increasing function w.r.t. arc length from an optimization perspective. We also propose to construct the conservative target labels which model the inlier and outlier noises using a wrapped unimodal-uniform mixture distribution. Unlike the one-hot setting, the conservative label makes the computation of Wasserstein distance more challenging. We systematically conclude the practical closed-form solution of Wasserstein distance for pose data with either one-hot or conservative target label. We evaluate our method on head, body, vehicle and 3D object pose benchmarks with exhaustive ablation studies. The Wasserstein loss obtaining superior performance over the current methods, especially using convex mapping function for ground metric, conservative label, and closed-form solution.
Thesis presentation created using the Beamer arrows template from TeXample.net
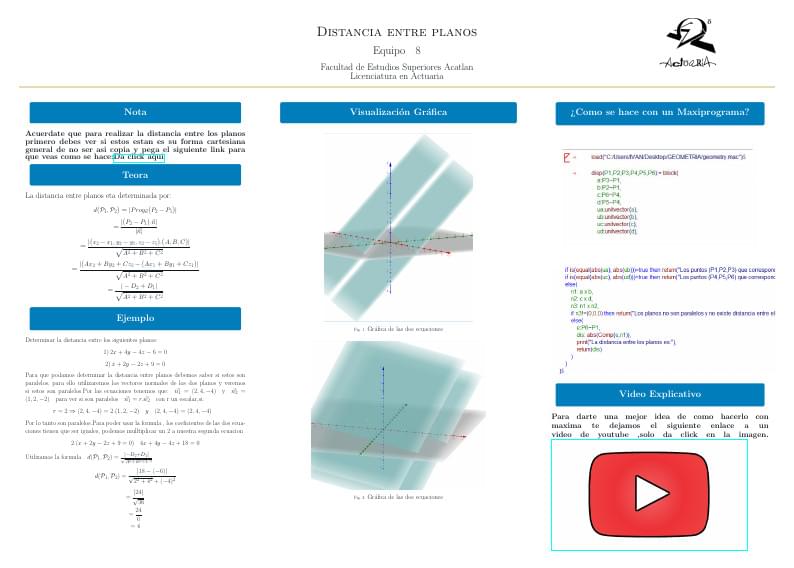
projecto geometria Acuerdate que para realizar la distancia entre los planos primero debes ver si estos estan es su forma cartesiana general de no ser asi copia y pega el siguiente link para que veas como se hace:Da click aqui
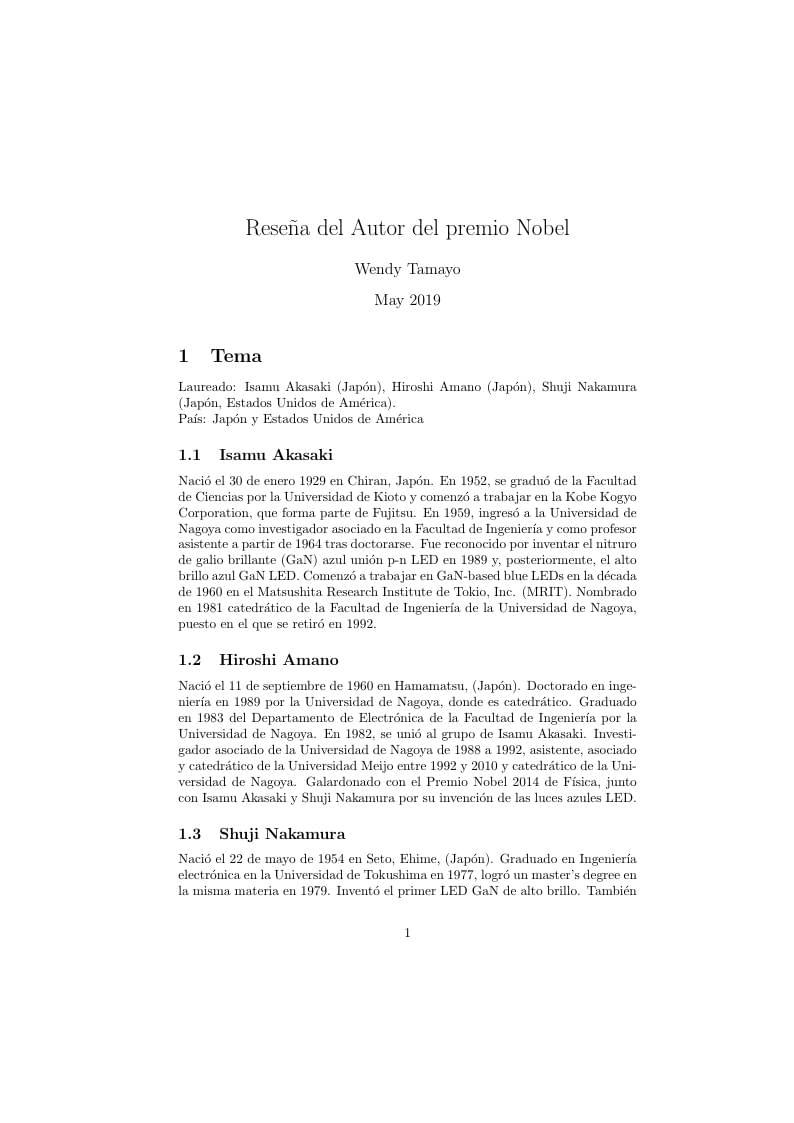
Reseña del Autor del premio Nobel
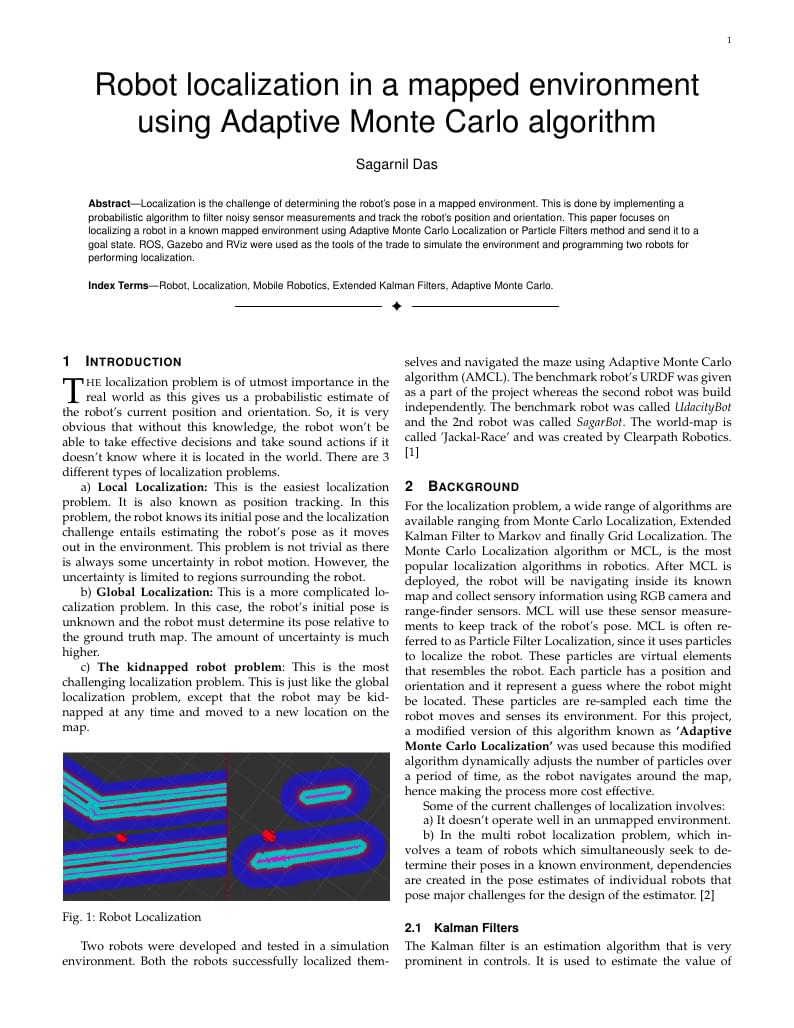
Localization is the challenge of determining the robot's pose in a mapped environment. This is done by implementing a probabilistic algorithm to filter noisy sensor measurements and track the robot's position and orientation. This paper focuses on localizing a robot in a known mapped environment using Adaptive Monte Carlo Localization or Particle Filters method and send it to a goal state. ROS, Gazebo and RViz were used as the tools of the trade to simulate the environment and programming two robots for performing localization.
rapport final
Short beamer to show how cat interact biotech and IT people
Installation instructions for XAMPP
The aim of this laboratory work is to design a strut/bracket assembly for aircrafts. Experiments are carried out to determine mechanical properties of certain materials.The material chosen is Mild Steel. Given the possible condition experienced by the material and the safety factor, the dimensions for the designs of the strut/bracket assembly for aircrafts are obtained to avoid failure by yield or fracture. The diameter of the pin, d ,which is subjected to shear stress should be larger than 14.56mm. The diameter of the rod, D, should be larger than 12.74mm. The thickness of the rod would be 10mm.
\begin
Discover why over 30 million people worldwide trust Overleaf with their work.